My research interests lie at the intersection of 3D computer vision and machine learning, spanning generalizable perception, structured representation, and verifiable modeling.
WACV 2027
BRepa: Graph-Based B-Rep Pretraining for Unified CAD Understanding and Generation
BRepA learns reusable representations of CAD boundary representations from unlabeled data. The model combines surface and edge encoders with graph attention to capture geometric detail and connectivity. Two masked-autoencoding tasks train it to recover missing geometry and topology. The resulting features support both shape segmentation and generative modeling: pretraining improves segmentation when annotations are scarce, while feature alignment helps B-Rep diffusion models converge faster and produce higher-quality shapes. Experiments on MFCAD and Fusion 360 show that a single pretrained backbone transfers across these discriminative and generative tasks.
@article{zhu2027brepa,title={BRepa: Graph-Based B-Rep Pretraining for Unified CAD Understanding and Generation},author={Zhu, Dekai and Chen, Zhaiyu and Gavranovic, Stefan and Ilic, Slobodan},journal={IEEE/CVF Winter Conference on Applications of Computer Vision},year={2027},}
CVPR 2026
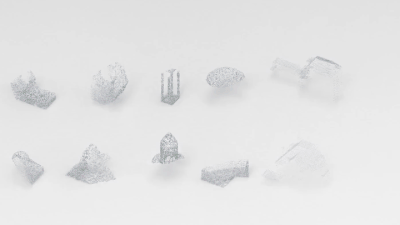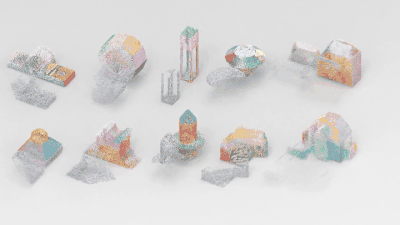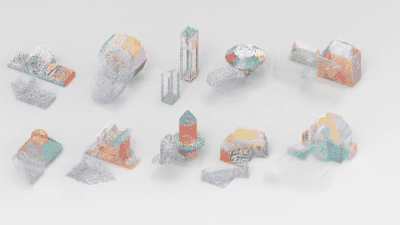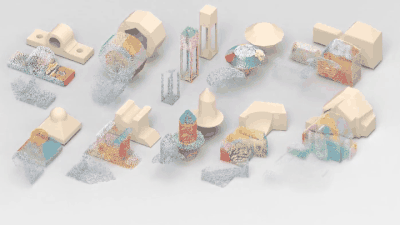
Unified Primitive Proxies for Structured Shape Completion
Structured shape completion recovers missing geometry as primitives rather than as unstructured points, which enables primitive-based surface reconstruction. Instead of following the prevailing cascade, we rethink how primitives and points should interact, and find it more effective to decode primitives in a dedicated pathway that attends to shared shape features. Following this principle, we present UniCo, which in a single feed-forward pass predicts a set of primitives with complete geometry, semantics, and inlier membership. To drive this unified representation, we introduce primitive proxies, learnable queries that are contextualized to produce assembly-ready outputs. To ensure consistent optimization, our training strategy couples primitives and points with online target updates. Across synthetic and real-world benchmarks with four independent assembly solvers, UniCo consistently outperforms recent baselines, lowering Chamfer distance by up to 50% and improving normal consistency by up to 7%. These results establish an attractive recipe for structured 3D understanding from incomplete data.
@article{chen2026unico,title={Unified Primitive Proxies for Structured Shape Completion},author={Chen, Zhaiyu and Wang, Yuqing and Zhu, Xiao Xiang},journal={IEEE/CVF Conference on Computer Vision and Pattern Recognition},year={2026},}
TGRS 2026
Reconstructing Building Height from Spaceborne TomoSAR Point Clouds Using a Dual-Topology Network
Reliable building height estimation is essential for various urban applications. Spaceborne SAR tomography (TomoSAR) provides weather-independent, side-looking observations that capture facade-level structure, offering a promising alternative to conventional optical methods. However, TomoSAR point clouds often suffer from noise, anisotropic point distributions, and data voids on incoherent surfaces, all of which hinder accurate height reconstruction. To address these challenges, we introduce a learning-based framework for converting raw TomoSAR points into high-resolution building height maps. Our dual-topology network alternates between a point branch that models irregular scatterer features and a grid branch that enforces spatial consistency. By jointly processing these representations, the network denoises the input points and inpaints missing regions to produce continuous height estimates. To our knowledge, this is the first proof of concept for large-scale urban height mapping directly from TomoSAR point clouds. Extensive experiments on data from Munich and Berlin validate the effectiveness of our approach. Moreover, we demonstrate that our framework can be extended to incorporate optical satellite imagery, further enhancing reconstruction quality.
@article{chen2026tomosar2height,title={Reconstructing Building Height from Spaceborne TomoSAR Point Clouds Using a Dual-Topology Network},journal={IEEE Transactions on Geoscience and Remote Sensing},year={2026},author={Chen, Zhaiyu and Wang, Yuanyuan and Shi, Yilei and Zhu, Xiao Xiang},doi={10.1109/TGRS.2026.3656340},}
NeurIPS 2025
Learning Generalizable Shape Completion with SIM(3) Equivariance
3D shape completion methods typically assume scans are pre-aligned to a canonical frame. This leaks pose and scale cues that networks may exploit to memorize absolute positions rather than inferring intrinsic geometry. When such alignment is absent in real data, performance collapses. We argue that robust generalization demands architectural equivariance to the similarity group, SIM(3), so the model remains agnostic to pose and scale. Following this principle, we introduce the first SIM(3)-equivariant shape completion network, whose modular layers successively canonicalize features, reason over similarity-invariant geometry, and restore the original frame. Under a de-biased evaluation protocol that removes the hidden cues, our model outperforms both equivariant and augmentation baselines on the PCN benchmark. It also sets new cross-domain records on real driving and indoor scans, lowering minimal matching distance on KITTI by 17% and Chamfer distance \ell1 on OmniObject3D by 14%. Perhaps surprisingly, ours under the stricter protocol still outperforms competitors under their biased settings. These results establish full SIM(3) equivariance as an effective route to truly generalizable shape completion.
@article{wang2025simeco,title={Learning Generalizable Shape Completion with SIM(3) Equivariance},journal={Advances in Neural Information Processing Systems},year={2025},author={Wang, Yuqing and Chen, Zhaiyu and Zhu, Xiao Xiang},}
JOSS 2025
abspy: A Python Package for 3D Adaptive Binary Space Partitioning and Modeling
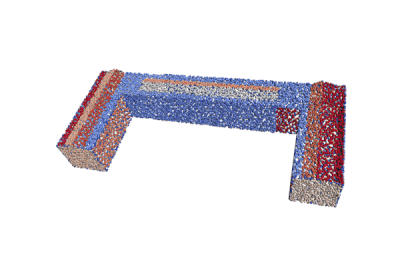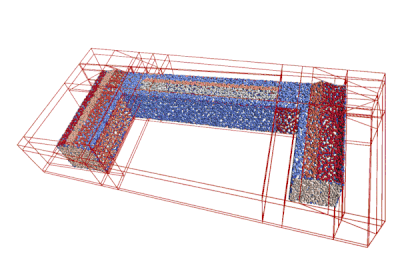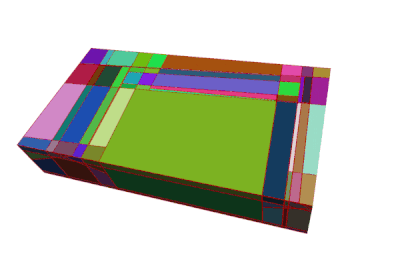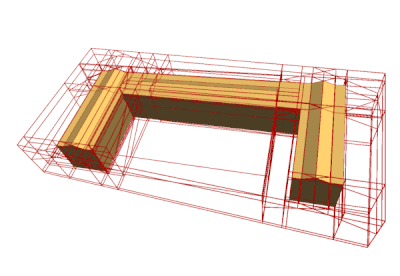
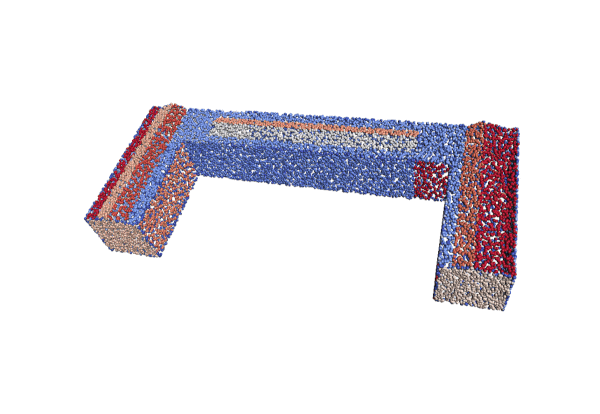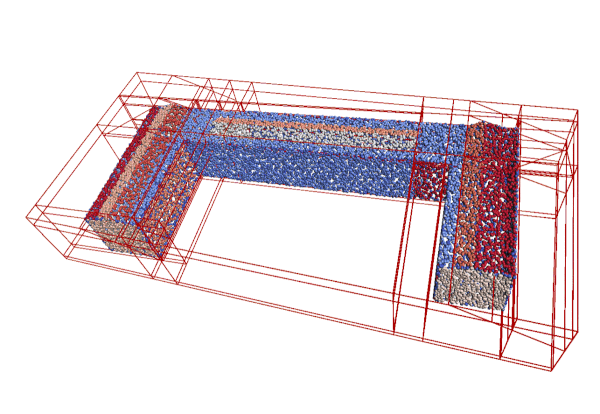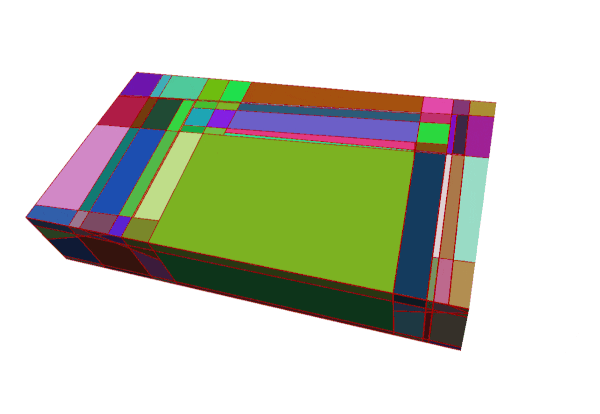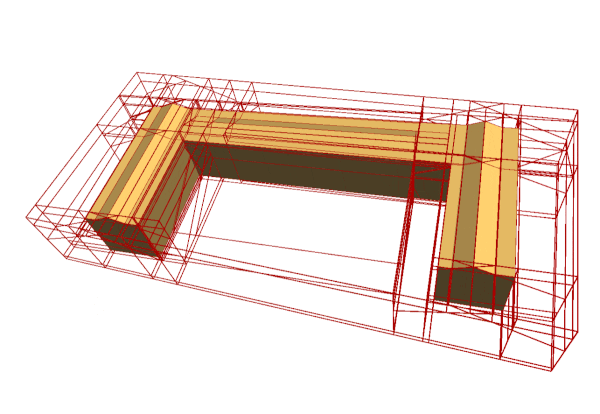
Efficient and robust space partitioning of 3D space underpins many applications in computer graphics. abspy is a Python package for adaptive binary space partitioning and 3D modeling. At its core, abspy constructs a plane arrangement by recursively subdividing 3D space with planar primitives to form a linear cell complex that reflects the underlying geometric structure. This adaptive scheme iteratively refines the spatial decomposition, producing a compact representation that supports efficient 3D modeling and analysis. Built on robust arithmetic kernels and interoperable data structures, abspy exposes a high-level Python API that lets researchers prototype advanced 3D pipelines such as surface reconstruction, volumetric analysis, and feature extraction for machine learning.
@article{chen2025abspy,title={abspy: A Python Package for 3D Adaptive Binary Space Partitioning and Modeling},journal={Journal of Open Source Software},year={2025},author={Chen, Zhaiyu},doi={10.21105/joss.07946},}
CVPR 2025
Parametric Point Cloud Completion for Polygonal Surface Reconstruction
Existing polygonal surface reconstruction methods heavily depend on input completeness and struggle with incomplete point clouds. We argue that while current point cloud completion techniques may recover missing points, they are not optimized for polygonal surface reconstruction, where the parametric representation of underlying surfaces remains overlooked. To address this gap, we introduce parametric completion, a novel paradigm for point cloud completion, which recovers parametric primitives instead of individual points to convey high-level geometric structures. Our presented approach, PaCo, enables high-quality polygonal surface reconstruction by leveraging plane proxies that encapsulate both plane parameters and inlier points, proving particularly effective in challenging scenarios with highly incomplete data. Comprehensive evaluations of our approach on the ABC dataset establish its effectiveness with superior performance and set a new standard for polygonal surface reconstruction from incomplete data.
@article{chen2025paco,title={Parametric Point Cloud Completion for Polygonal Surface Reconstruction},journal={IEEE/CVF Conference on Computer Vision and Pattern Recognition},year={2025},author={Chen, Zhaiyu and Wang, Yuqing and Nan, Liangliang and Zhu, Xiao Xiang},}
ISPRS 2024
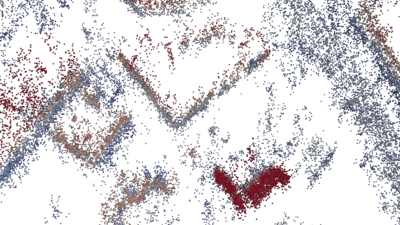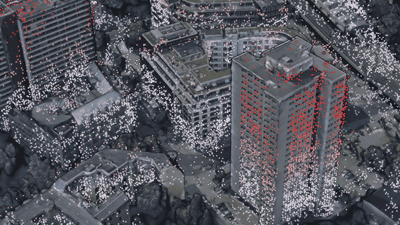
PolyGNN: Polyhedron-based Graph Neural Network for 3D Building Reconstruction from Point Clouds
We present PolyGNN, a polyhedron-based graph neural network for 3D building reconstruction from point clouds. PolyGNN learns to assemble primitives obtained by polyhedral decomposition via graph node classification, achieving a watertight and compact reconstruction. To effectively represent arbitrary-shaped polyhedra in the neural network, we propose a skeleton-based sampling strategy to generate polyhedron-wise queries. These queries are then incorporated with inter-polyhedron adjacency to enhance the classification. PolyGNN is end-to-end optimizable and is designed to accommodate variable-size input points, polyhedra, and queries with an index-driven batching technique. To address the abstraction gap between existing city-building models and the underlying instances, and provide a fair evaluation of the proposed method, we develop our method on a large-scale synthetic dataset with well-defined ground truths of polyhedral labels. We further conduct a transferability analysis across cities and on real-world point clouds. Both qualitative and quantitative results demonstrate the effectiveness of our method, particularly its efficiency for large-scale reconstructions.
@article{chen2024polygnn,title={PolyGNN: Polyhedron-based Graph Neural Network for 3D Building Reconstruction from Point Clouds},journal={ISPRS Journal of Photogrammetry and Remote Sensing},volume={218},pages={693-706},year={2024},issn={0924-2716},doi={10.1016/j.isprsjprs.2024.09.031},author={Chen, Zhaiyu and Shi, Yilei and Nan, Liangliang and Xiong, Zhitong and Zhu, Xiao Xiang},}
ISPRS 2022
Reconstructing Compact Building Models from Point Clouds using Deep Implicit Fields
While three-dimensional (3D) building models play an increasingly pivotal role in many real-world applications, obtaining a compact representation of buildings remains an open problem. In this paper, we present a novel framework for reconstructing compact, watertight, polygonal building models from point clouds. Our framework comprises three components: (a) a cell complex is generated via adaptive space partitioning that provides a polyhedral embedding as the candidate set; (b) an implicit field is learned by a deep neural network that facilitates building occupancy estimation; (c) a Markov random field is formulated to extract the outer surface of a building via combinatorial optimization. We evaluate and compare our method with state-of-the-art methods in generic reconstruction, model-based reconstruction, geometry simplification, and primitive assembly. Experiments on both synthetic and real-world point clouds have demonstrated that, with our neural-guided strategy, high-quality building models can be obtained with significant advantages in fidelity, compactness, and computational efficiency. Our method also shows robustness to noise and insufficient measurements, and it can directly generalize from synthetic scans to real-world measurements.
@article{chen2022points2poly,title={Reconstructing Compact Building Models from Point Clouds using Deep Implicit Fields},journal={ISPRS Journal of Photogrammetry and Remote Sensing},volume={194},pages={58-73},year={2022},issn={0924-2716},doi={10.1016/j.isprsjprs.2022.09.017},author={Chen, Zhaiyu and Ledoux, Hugo and Khademi, Seyran and Nan, Liangliang},}